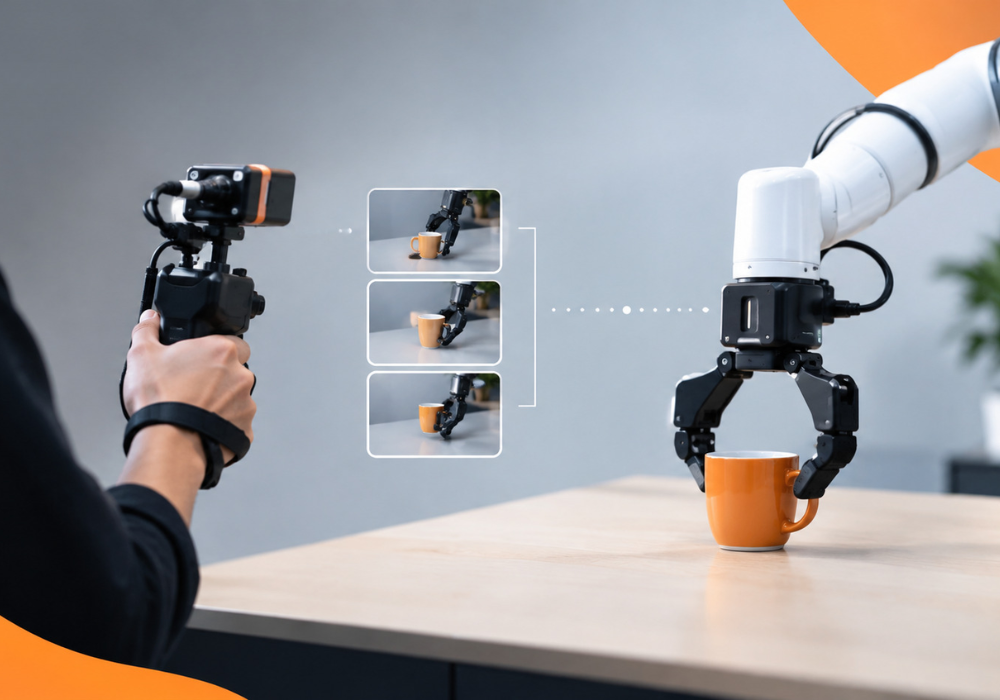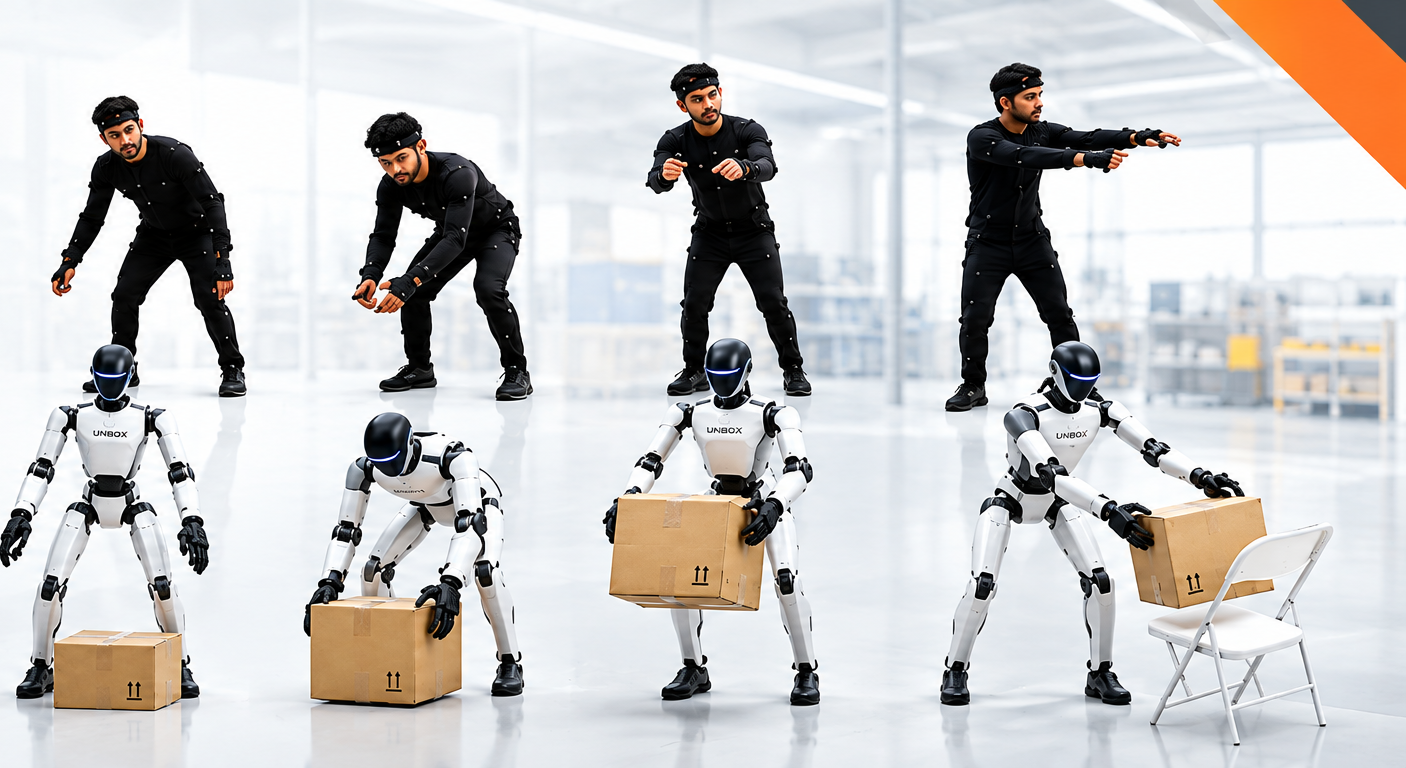
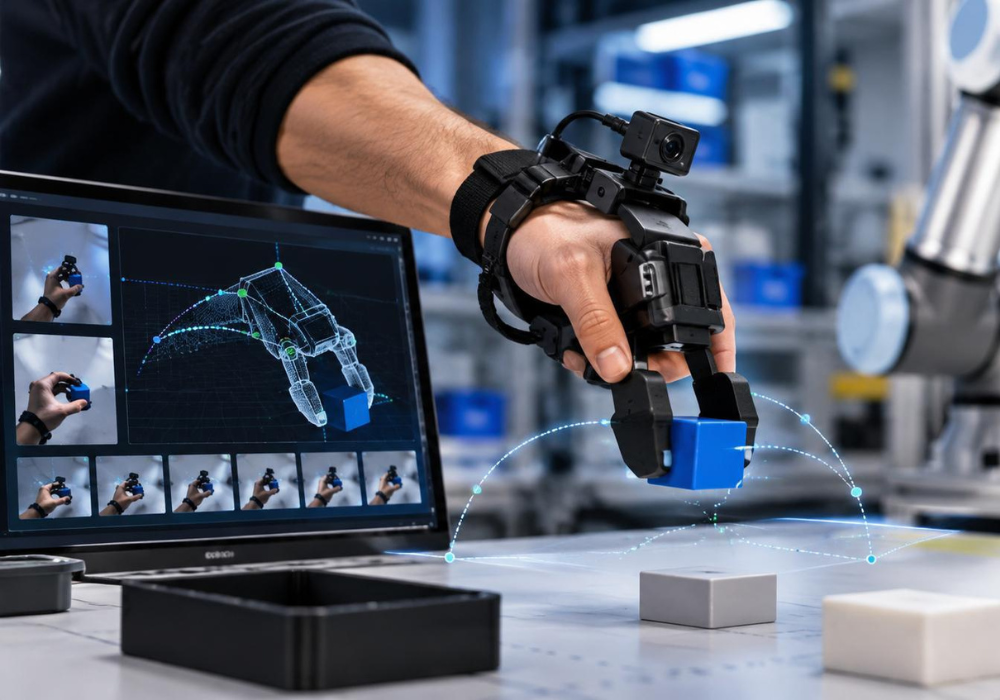
UMI demonstrations can be used within suitable robot learning pipelines. Whether a dataset is appropriate depends on its format, quality, task coverage, and compatibility
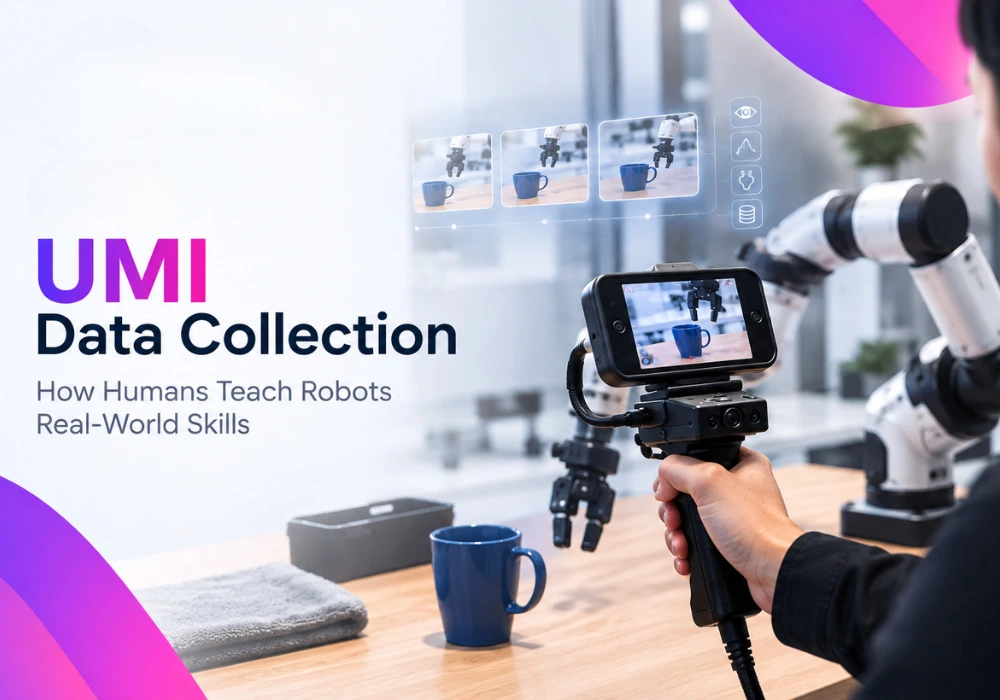
Robots are getting better at seeing, moving and interacting with the world. But there is still one major challenge: data. A robot cannot learn physical skills from images or text alone. To pick up a cup, open a drawer, fold a cloth or place an object accurately.
UMI data collection captures human manipulation demonstrations to create practical training data for robots, supporting robot learning and Physical AI applications.