18 Sep 26 UMI Data Collection: How Human Demonstrations Train Robots nferent_admin No Comments UMI data collection captures human manipulation demonstrations to create practical training data for robots, supporting robot learning and Physical AI applications. Read More
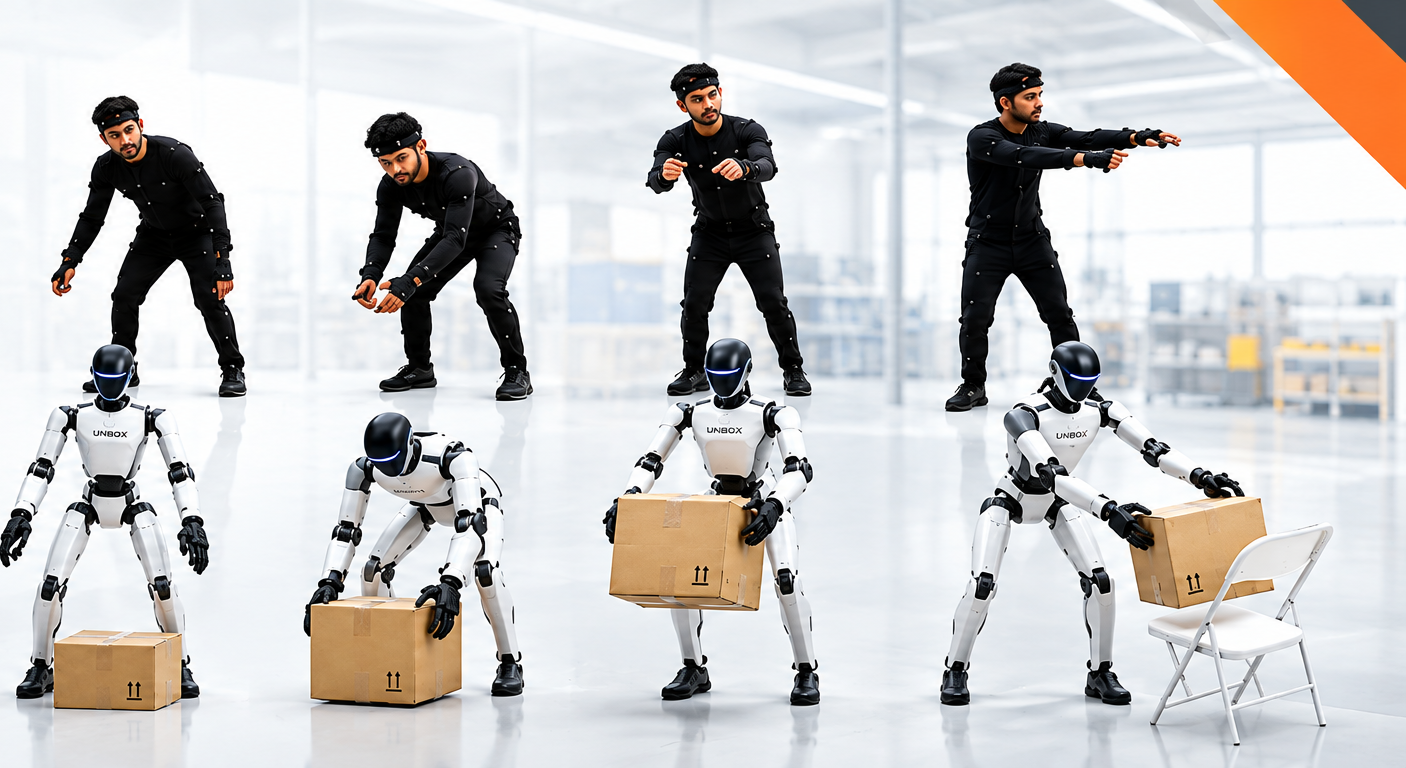
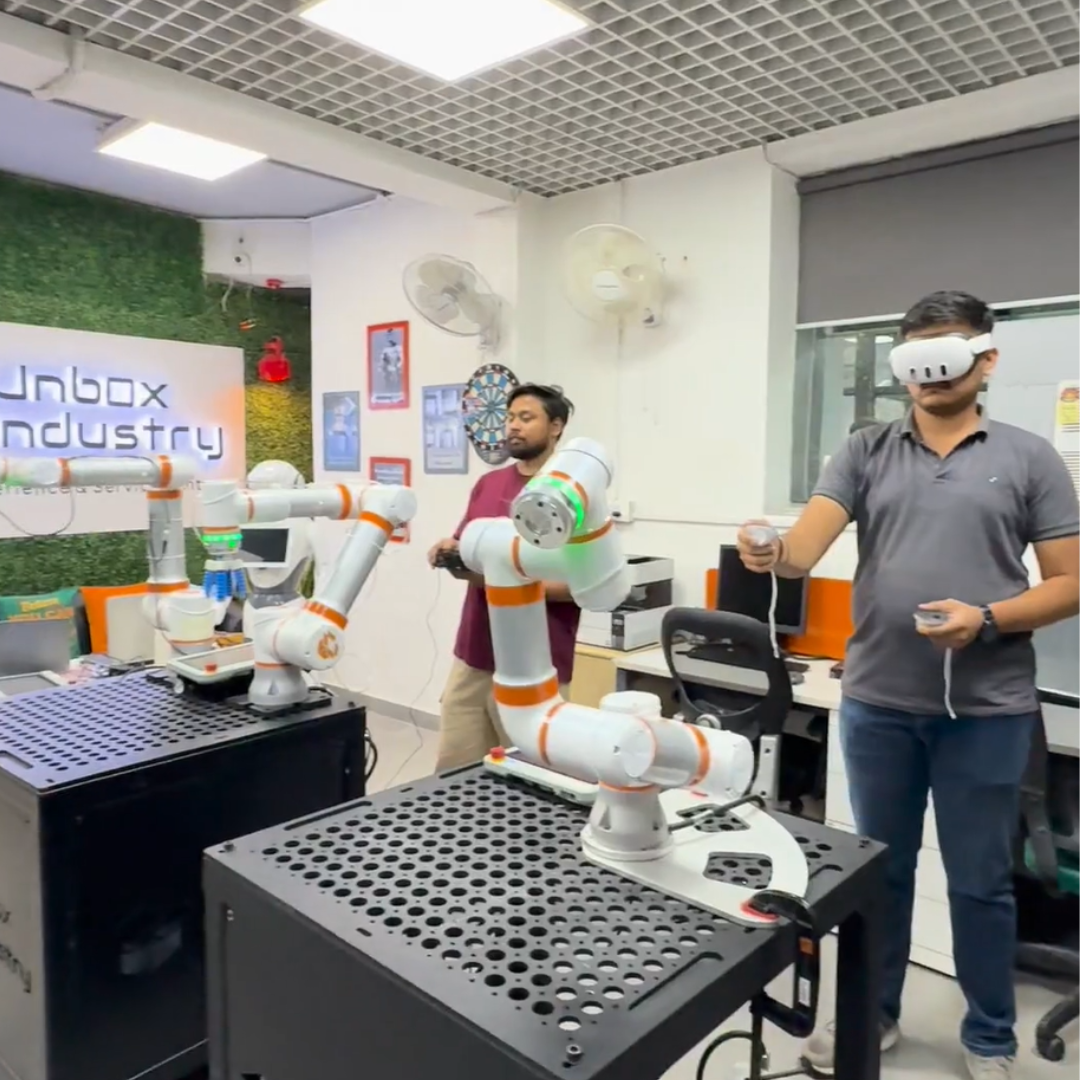
08 Sep 26 Teleoperation of Humanoid Robots nferent_admin No Comments How teleoperation powers humanoid robots, and how Nferent AI turns piloted motion into training data for robot foundation models. Read More
01 Sep 26 Teleoperation Data Collection Robots Aman Jain No Comments Teleoperation data collection robots let human operators remotely control robotic arms and hands to perform real world tasks grasping objects. Read More
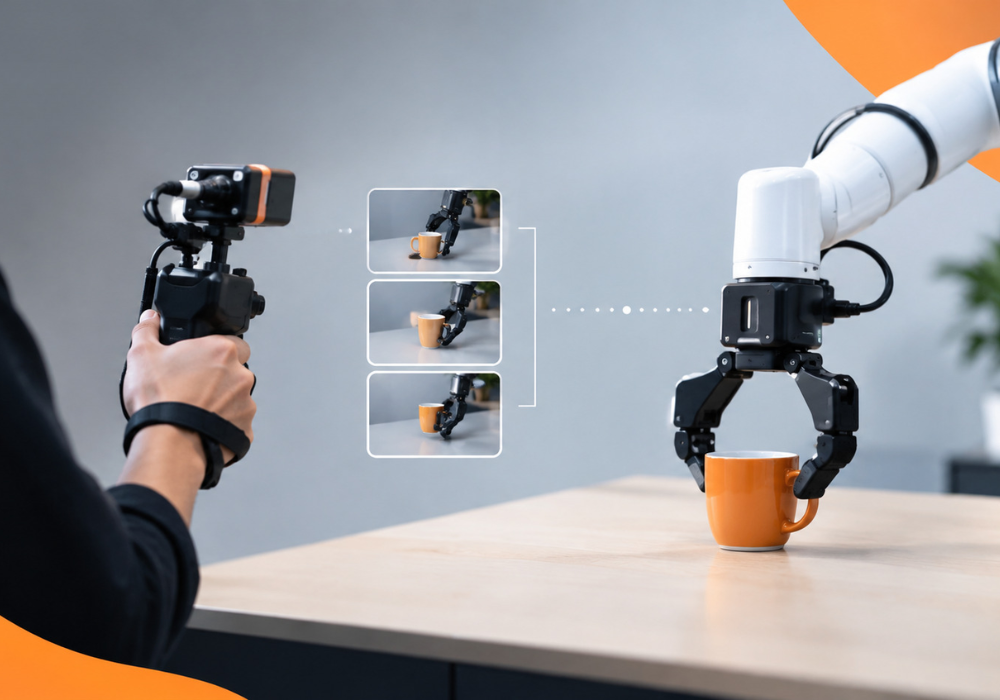
25 Aug 26 UMI Gripper Data Collection Aman Jain No Comments The UMI gripper a handheld, camera equipped device lets anyone collect robot training data by hand, no robot required. Read More